Browse docs
Choose a view
Start with the field you want to inspect. A video shows appearance; a chart shows change; a trajectory or 3D scene shows motion in space. The examples below include complete configs over public data.
All views accept width, height, and aspectRatio. Time-based views share
the episode cursor. Pair 3D scenes with a timeline or chart so you can change
time while keeping the scene pointer for orbiting.
videoStack
Compare camera streams at the same episode time. Bind video or image fields to
cameras; use columns to arrange the tiles. This example adds hand keypoints
and interval captions through overlays. as selects the annotation type,
and on associates an overlay with a particular camera.
Code .dreamrc.yaml
frameStack
Use frameStack when each camera is stored as encoded frames. The cursor selects
a frame to load, with nearby frames prefetched. The recording's fps maps frame
indices to seconds. Check image-codec support in the browser used to view it.
Code .dreamrc.yaml
lineChart
Bind a scalar or vector to series to see how it changes with time. A vector
becomes a family of traces. Here the two action columns are target x/y positions;
unit: px labels their stored units without converting them. Use an explicit
yRange when comparing the same signal across episodes.
lineWidth sets the chart-wide width in CSS pixels (default 2); a series entry's
width overrides it. activeLineWidth sets the emphasized width when series
identification is active, with a floor at the resolved base width. By default
active traces use 1.65 times that base. These options pass through to
EpisodeLineChart,
including highlightOnHover: true when pointer identification is wanted.
Keep reference traces readable with dash and opacity instead of hairline widths.
Code .dreamrc.yaml
trajectory2d
An xy path shows where the target moved. The view uses columns named x and
y, or the first two columns. invertY defaults to image coordinates; set it
to false for upward-positive y. A window limits the displayed path to seconds
around the cursor.
Set lineWidth for the whole view (default 2 CSS pixels), and width on a
series entry to override one path. activeLineWidth sets the recent trail's
width; its default is 1.65 times the path width, and an explicit value never
thins the base path. This changes stroke styling only: coordinates, missing-value
gaps, cursor lookup and seek times keep their existing behavior. Widths do not
scale with the SVG viewBox. Zero hides both the base and trail strokes but keeps
the cursor marker and recorded data. Negative or non-finite values use the same
fallback rules as the line chart.
Code .dreamrc.yaml
timeline
Bind labelled intervals to tracks. WebVTT files, string columns, and integer
columns with label tables can supply them. With no tracks, a known episode
duration still gives you a ruler. controls: false hides the playback bar.
Code .dreamrc.yaml
bandTrack
Use bands for flags and categorical states, such as an open/closed gripper.
Each column becomes a row of contiguous equal-value runs. maxLevels defaults
to 12; a column with more values shows a note suggesting a line chart instead.
Code .dreamrc.yaml
depthStack
Bind depth fields explicitly to cameras. Values are colorized; zero and invalid
readings are transparent. Set min and max to compare frames on the same
color scale. Otherwise, each frame uses its own valid range. colormap accepts
turbo or gray.
Code .dreamrc.yaml
pointCloud
Bind one xyz or xyz/rgb field to cloud. The scene fits its camera to the first
frame and follows the shared cursor. Set up to match your coordinate system;
the default is z-up. Use the adjacent chart to scrub while the scene pointer
remains available for orbiting.
Code .dreamrc.yaml
recon3d
Bind scene files to geometry and motion fields to tracks. A rigid pose,
deforming mesh, and point set use as: transform3d, vertices3d, and pose3d
respectively. Object tracks join named geometry nodes. Set up for the data
frame; trail controls how much motion appears around the cursor.
Code .dreamrc.yaml
metaPanel
Show the episode name, duration, frame rate, and task text supplied by its
reader. Use note for a short explanation of the recording and showTasks: false
when repeated task text adds little to an episode list.
Code .dreamrc.yaml
fields
Inspect field addresses, types, and shapes before writing bindings. The field
name is what goes into cameras, series, or another slot. Display labels can
be changed without changing that address.
Code .dreamrc.yaml
For a camera and chart in one row, see layout. For a URDF driven by tf or joint states, see robot motion. Function-valued options such as tick formatters belong in the React component API; they cannot be supplied by YAML.
usd
Render one static .usd, .usda, .usdc or .usdz scene. Bind exactly one
file field with scene: [scene]. The package includes the real renderer,
worker and WASM; no DreamLake application registration is needed.
Code .dreamrc
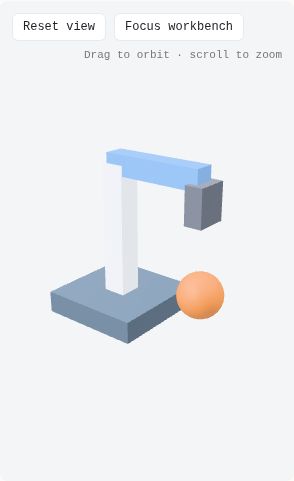
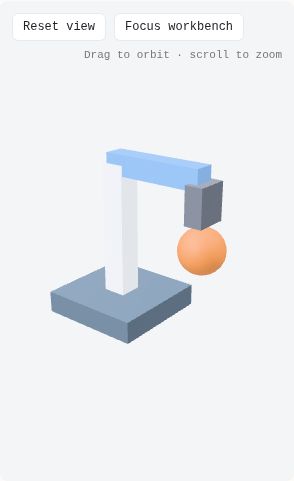
This live example composes an authored robot from a sibling USDA layer and renders its geometry and colors. Download the config, scene, second scene, robot layer and scene index, pick thumbnail, place thumbnail and HTTP index to run it on your own static server.
| Parameter | Default | Behavior |
|---|---|---|
scene | required | Exactly one file field; wildcards are accepted only if they resolve to one field |
height | 480 | Pixels or CSS size such as 70vh; parent row slots can supply the height |
framing | scene | Fit non-planar subject bounds; workbench focuses the upper 62% of those bounds |
focusPaths | [] | USD prim path prefixes used in workbench framing; empty uses the upper-bounds heuristic |
cameraDirection | [-1, 0.65, 0.18] | Non-zero finite direction from target to camera, normalized before fitting |
maxTextureSize | 2048 | Integer 128–2048; use 512 for offline thumbnail generation to reduce decoder/GPU work |
exposure | 1.0 | Positive tone-mapping exposure, maximum 4 |
Drag to orbit, right-drag to pan and scroll/pinch to zoom. Reset view restores the configured framing. Focus workbench / Show full scene changes framing without reloading geometry. Loading reports layers, geometry and textures; failures offer Retry and unsupported content is listed in warnings.
Search is not part of this view. The example explicitly selects the public collection browser; see collection configuration and resource injection API.
USD is a static preview, not a simulator or animation player. Renderer support is bounded by the shipped OpenUSD reader; unsupported primitives/materials may produce warnings. USDZ embedded resources are supported. Loose dependencies must remain inside the allowed root and use HTTP(S), CORS-readable URLs without redirects. Public resolution defaults to the entry file's directory; private or signed storage must inject authorized resolution. Authored external URLs are rejected. UDIM PNG atlases require an explicit file manifest listing their tiles.
Only a selected scene downloads. Rendering runs on demand with DPR capped at 1.5, textures capped at 2048 pixels, four concurrent fetches, 256 MiB layer and texture budgets, a 512 MiB network budget and at most 2048 dynamic dependency requests. Large images have additional decoder limits. Switching/unmounting aborts work, terminates its worker and disposes geometry, textures and materials. These are resource caps, not a promise that every scene below them fits every GPU.